Products

roboX-series
roboX-link
Device and controller connection middleware
Connect PLCs, motion controllers, robots, TCP/IP, EtherCAT, Modbus, and other device networks into the digital twin platform.
Key Capabilities
EtherCAT motion controller support
Digital In/Out connection
TCP/IP and RS-232 external devices
Direct and network link
Key Features & Characteristics
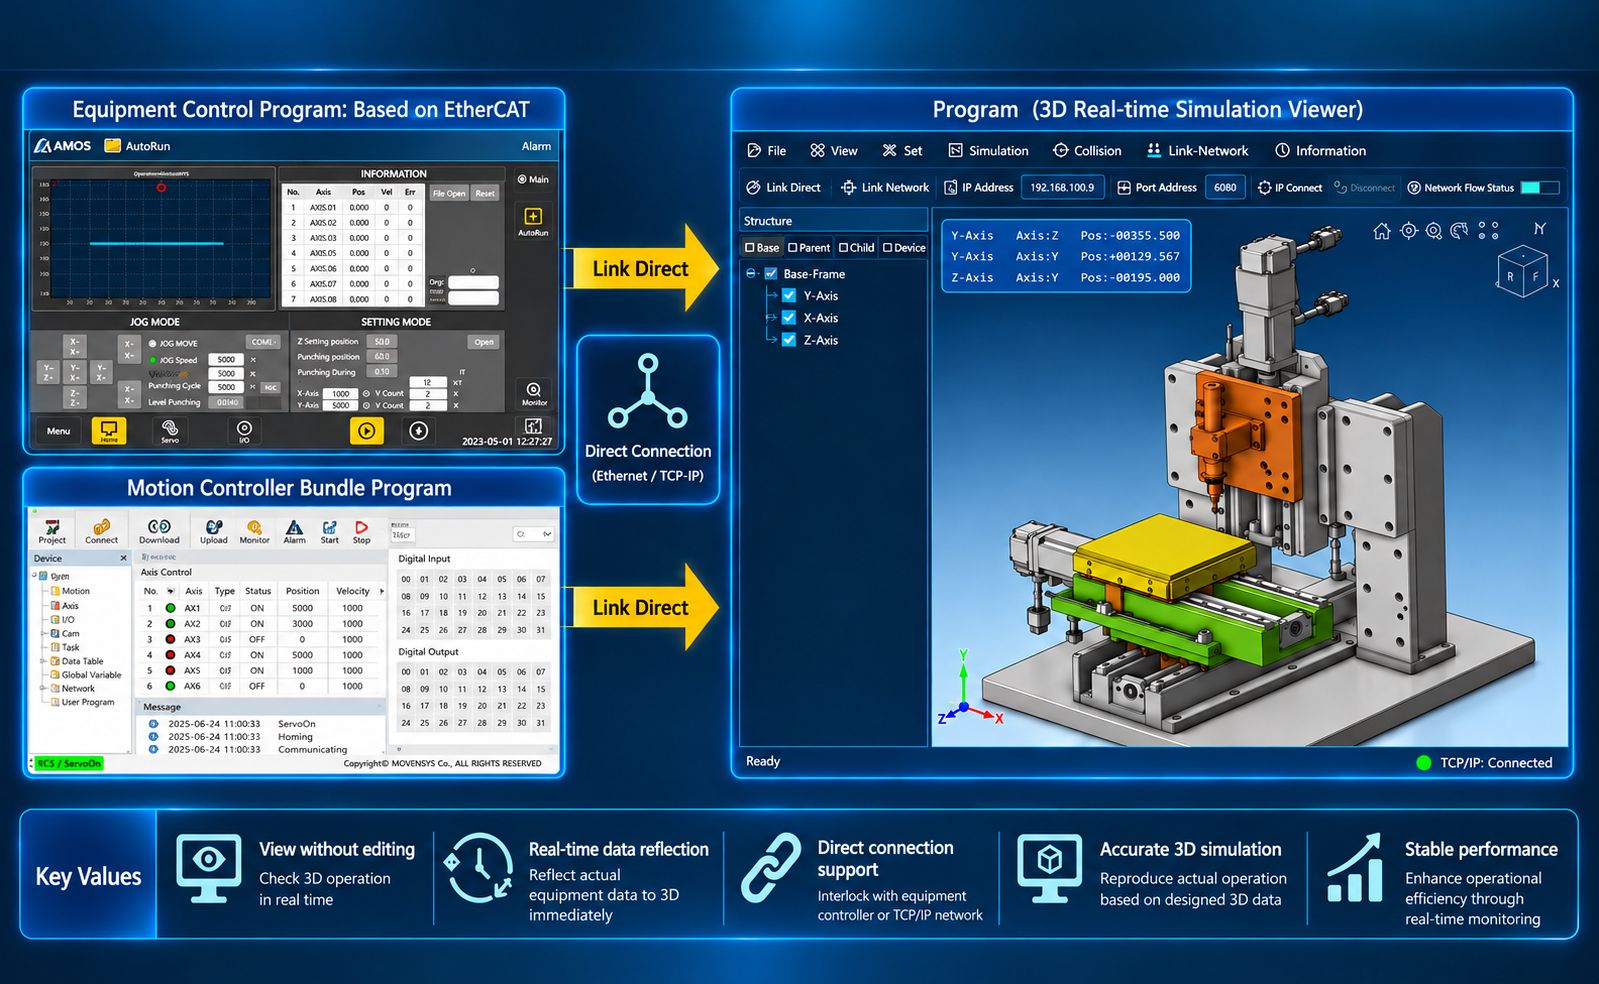
Direct / Network Link Architecture
- Links factory equipment-control programs with office or maintenance-room viewers.
- Supports EtherCAT, digital I/O, TCP/IP, and RS-232 device connections.
Direct / Network Link Operation
- Links factory equipment-control programs with roboX-link through direct connection.
- Connects office or maintenance-room 3D real-time simulation viewers through the network.
- Role
- Connect
- Protocols
- TCP/IP, EtherCAT, Modbus
- Setup
- No-code mapping
Use Cases
- Multi-controller integration
- Equipment data connection
- Legacy device integration
Product Details by Function
Direct link
- Connect factory equipment control programs with roboX-link
- Bridge equipment-control PCs and link software for data exchange
- Integrate ECAT-based control and motion controller bundle programs
Network link
- Connect roboX-viewer from office or maintenance rooms
- Transfer equipment data over Ethernet / TCP-IP
- Improve remote monitoring and maintenance efficiency
Device compatibility
- EtherCAT motion controllers
- EtherCAT digital In/Out
- TCP/IP and RS-232 external devices